top of page
Ryan Stockton
Senior Robotics Engineer with extensive experience designing and developing novel actuators and precision mechanisms for extreme environments
Ryan Stockton
Senior Robotics Engineer with extensive experience designing and developing novel actuators and precision mechanisms for extreme environments
Lunar Terrain Vehicle Mobility System
I was the Lead Mobility Engineer on NASA's Lunar Terrain Vehicle- Ground Test Unit (LTV GTU). The LTV-GTU is a feature-rich ground test vehicle designed to be reconfigurable for ground testing and conceptual operations development for various NASA and contractor payloads.
As the Lead Mobility Engineer I was responsible for the architecture, design, manufacturing, integration, and testing of the vehicles mobility system.
I was the sole designer of the propulsion actuators and wheels and completed the final 20% of design work on the suspension and steering actuators and pushed them through manufacturing.
The vehicle consists of 4 identical wheel modules. Each wheel module has two propulsion actuators, a non-backdrivable steering actuator, and a non-backdrivable suspension actuator.
The propulsion actuator is comprised of 2x Parker frameless BLDC motors driving a 3 stage modified COTS planetary geartrain. Commutation is provided by a resolver integrated on the front of the motor rotor.
The steering actuator utilizes a Parker framless BLDC motor, driving a 2 stage modified COTS planetary geartrain that in turn drives a 50:1 worm gear to achieve non-backdrivability. Commutation is provided by a resolver integrated on the back of the motor, absolution position is achieved with a Zettlex inductive encoder. This actuator contains a cascading rotary hard-stop that allows the actuator to have hard-stops at both ends of travel with 600 degrees of output rotation. This cascading hard-stop technology is undergoing review by the NASA Technology Transfer Office to pursue at patent.
The suspension actuator utilizes a Parker frameless BLDC motor driving a custom 4:1 planetary geartrain that is housed inside of the flex-spline of a Harmonic Drive gearset. This drives a 50:1 worm gear to achieve non-backdrivability.
I also designed the vehicles avionics boxes which integrated 6x Elmo motor controllers, custom bus bars, low voltage control devices, and over-voltage shunt resistor. There is one avionics box per wheel module installed in the chassis towers and the boxes are designed to be water resistant.
Project type
NASA Project
Date
May 2021-Present
Location
Houston, TX

01
Lunar Terrain Vehicle Mobility System

01
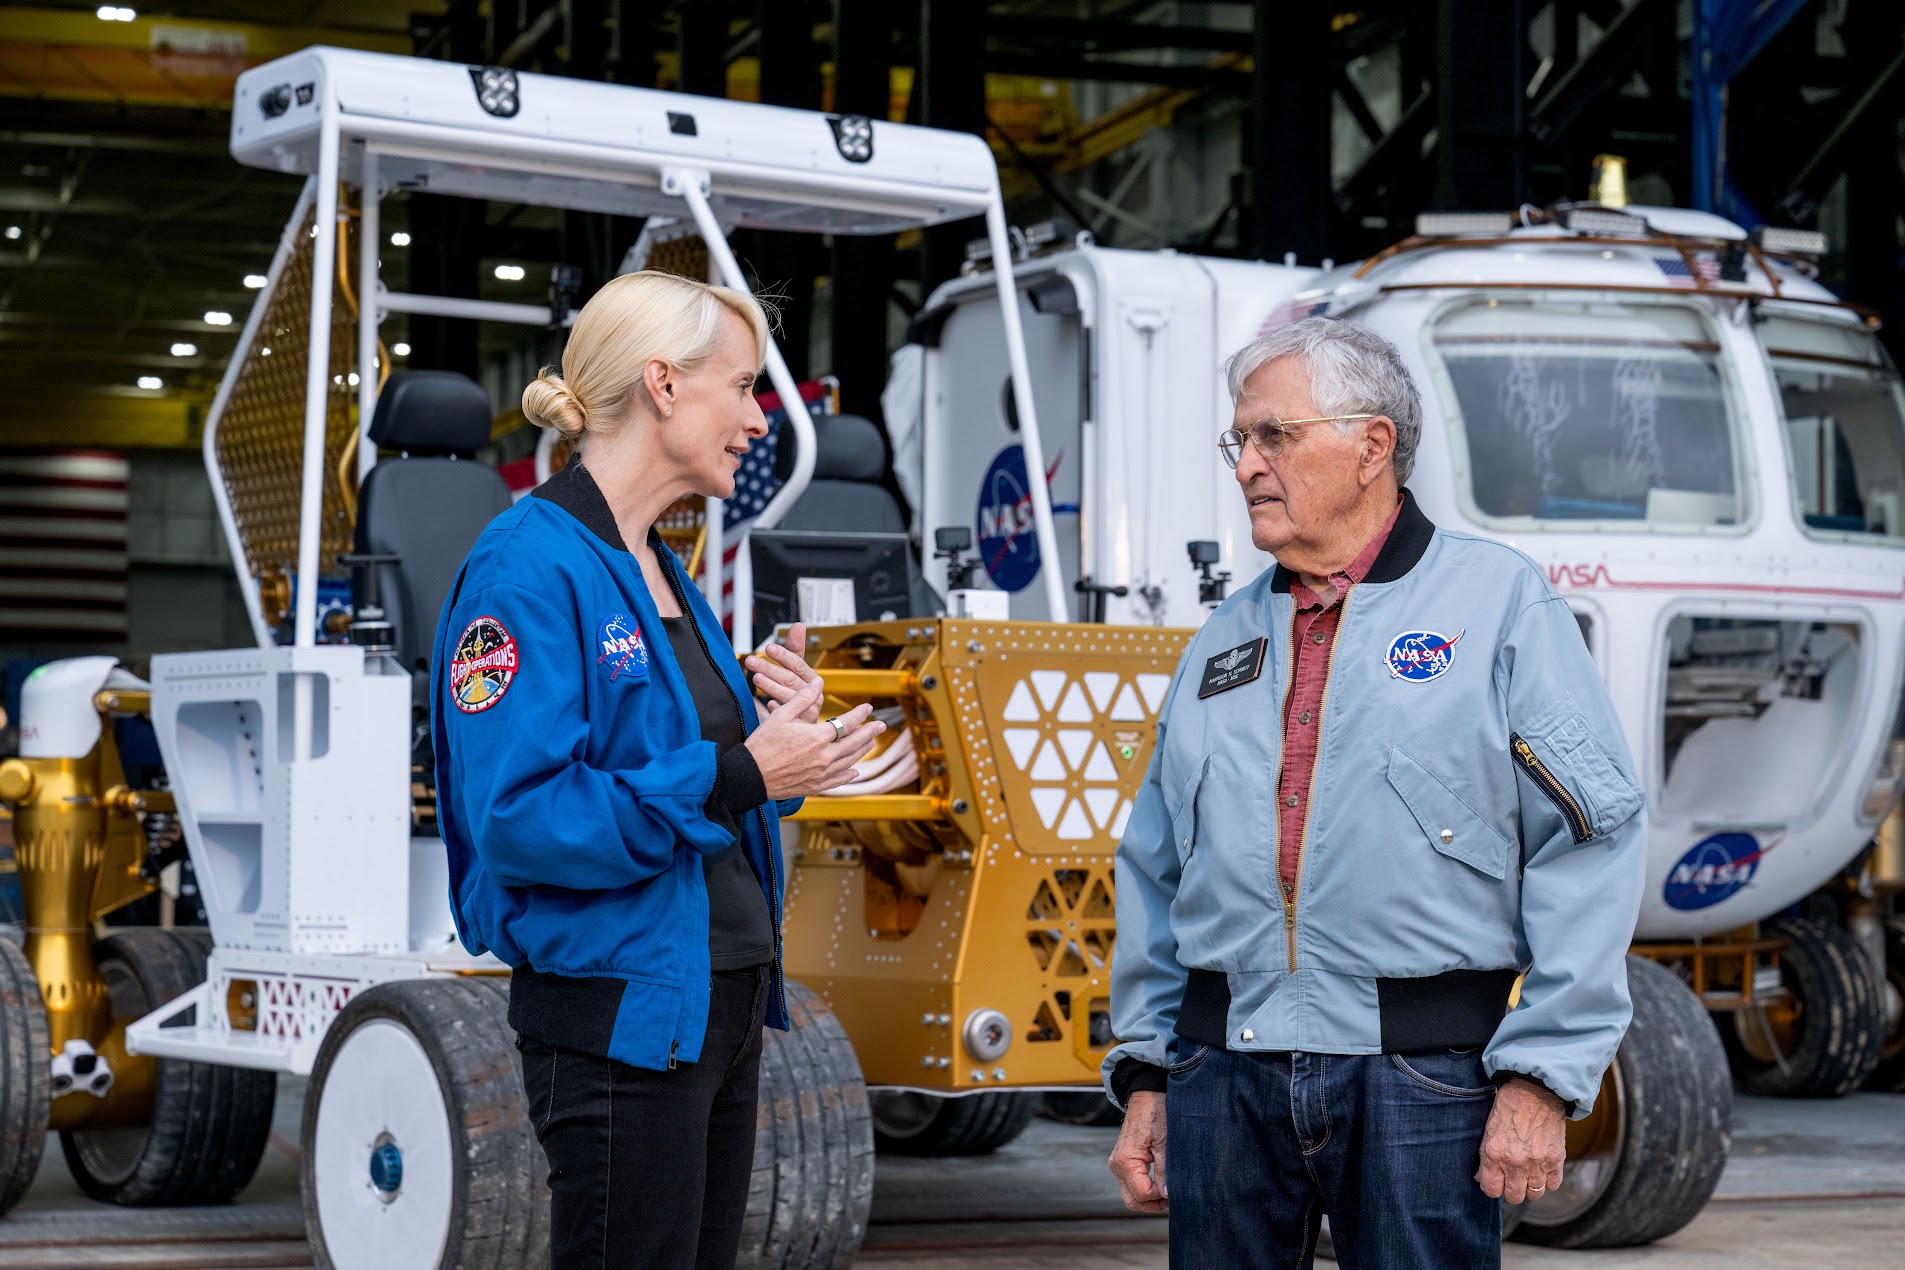
Apollo 17 Astronaut Jack Schmitt
NASA Astronaut Kate Rubins and Apollo 17 Astronaut Jack Schmitt prepare to drive the LTV rover.

02
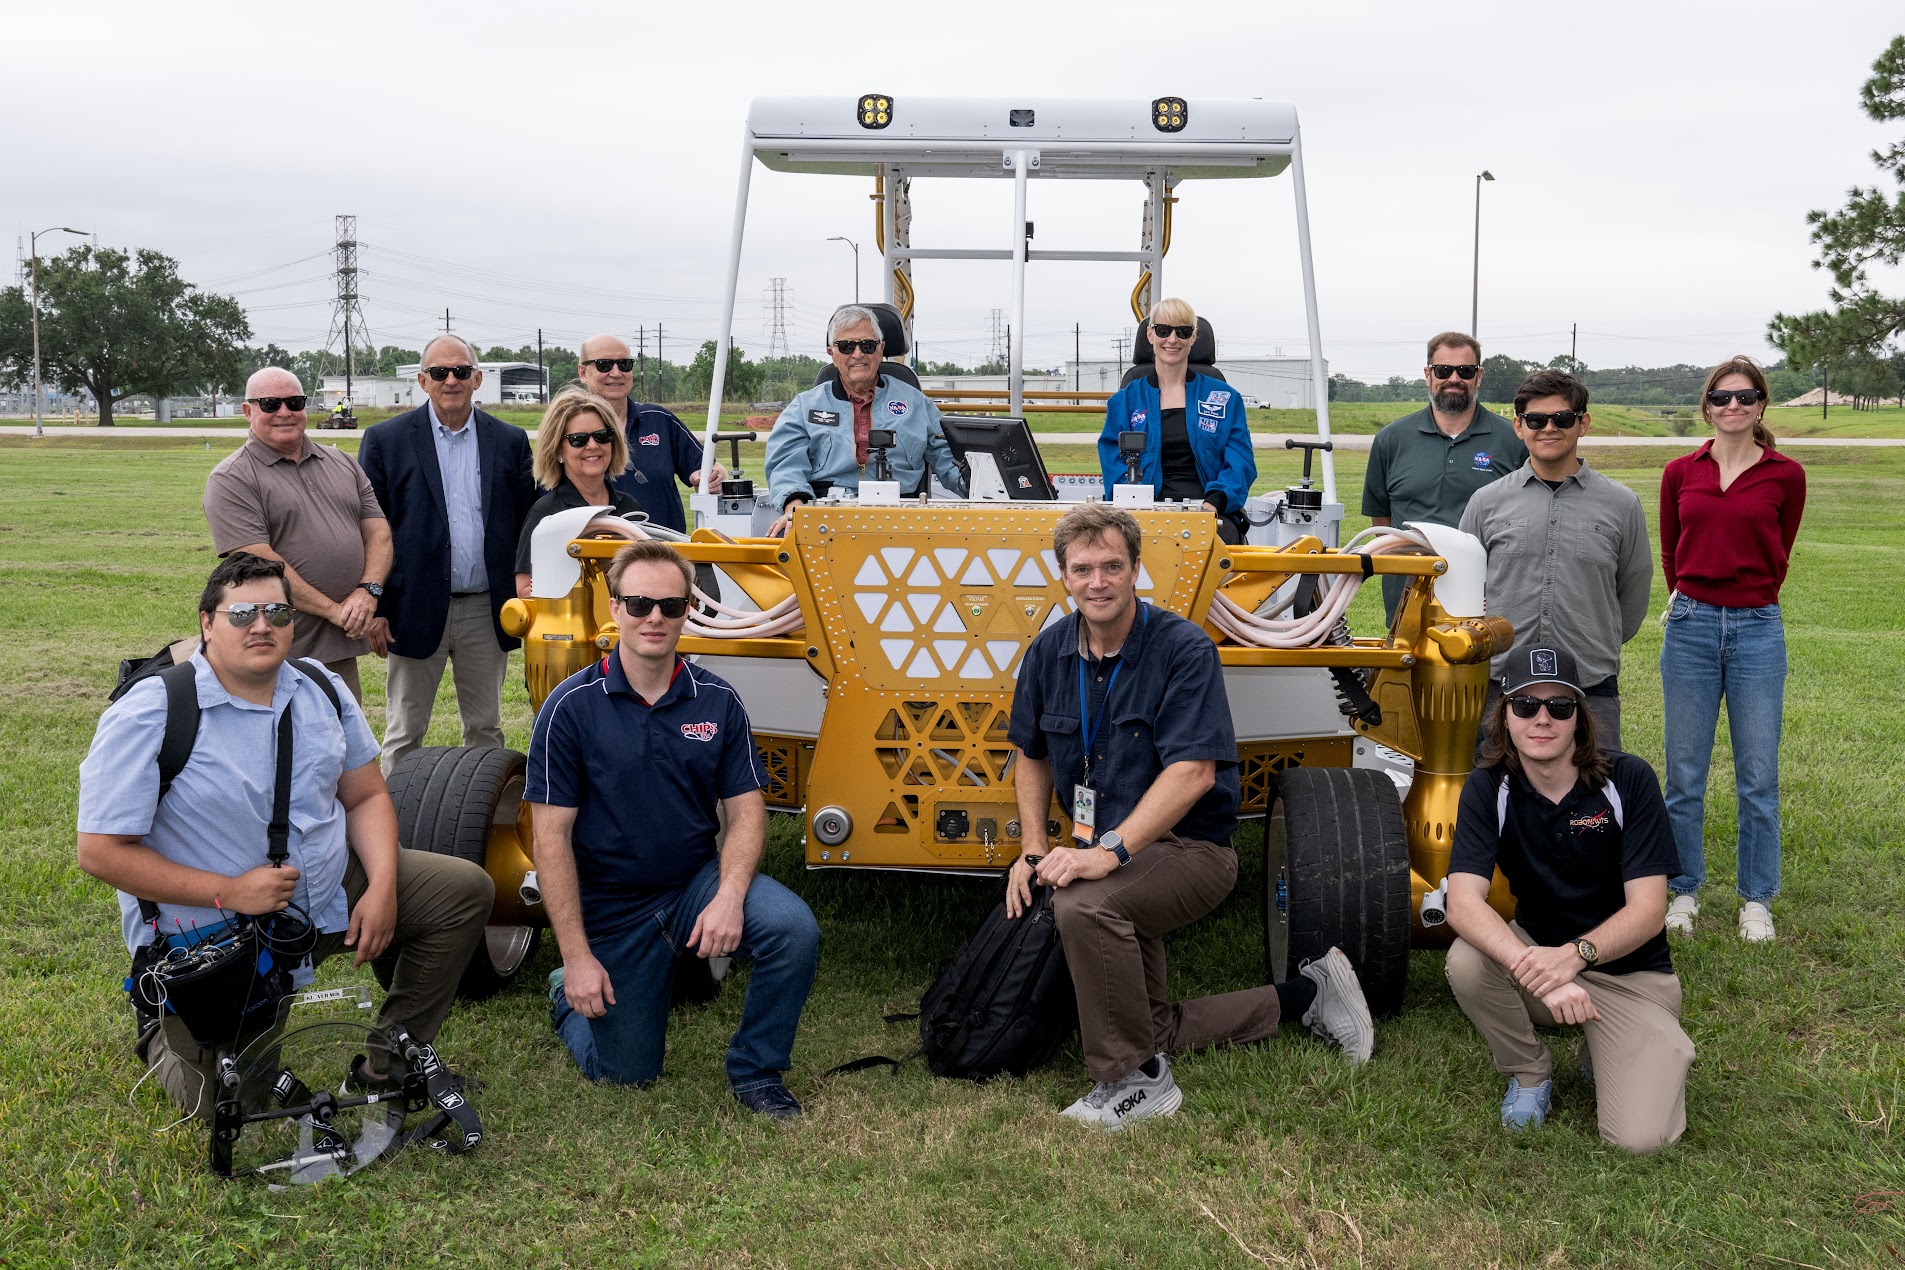
Apollo 17 Astronaut Jack Schmitt 2
Apollo Astronaut Jack Schmitt and the engineering and PAO teams after driving the LTV rover

03
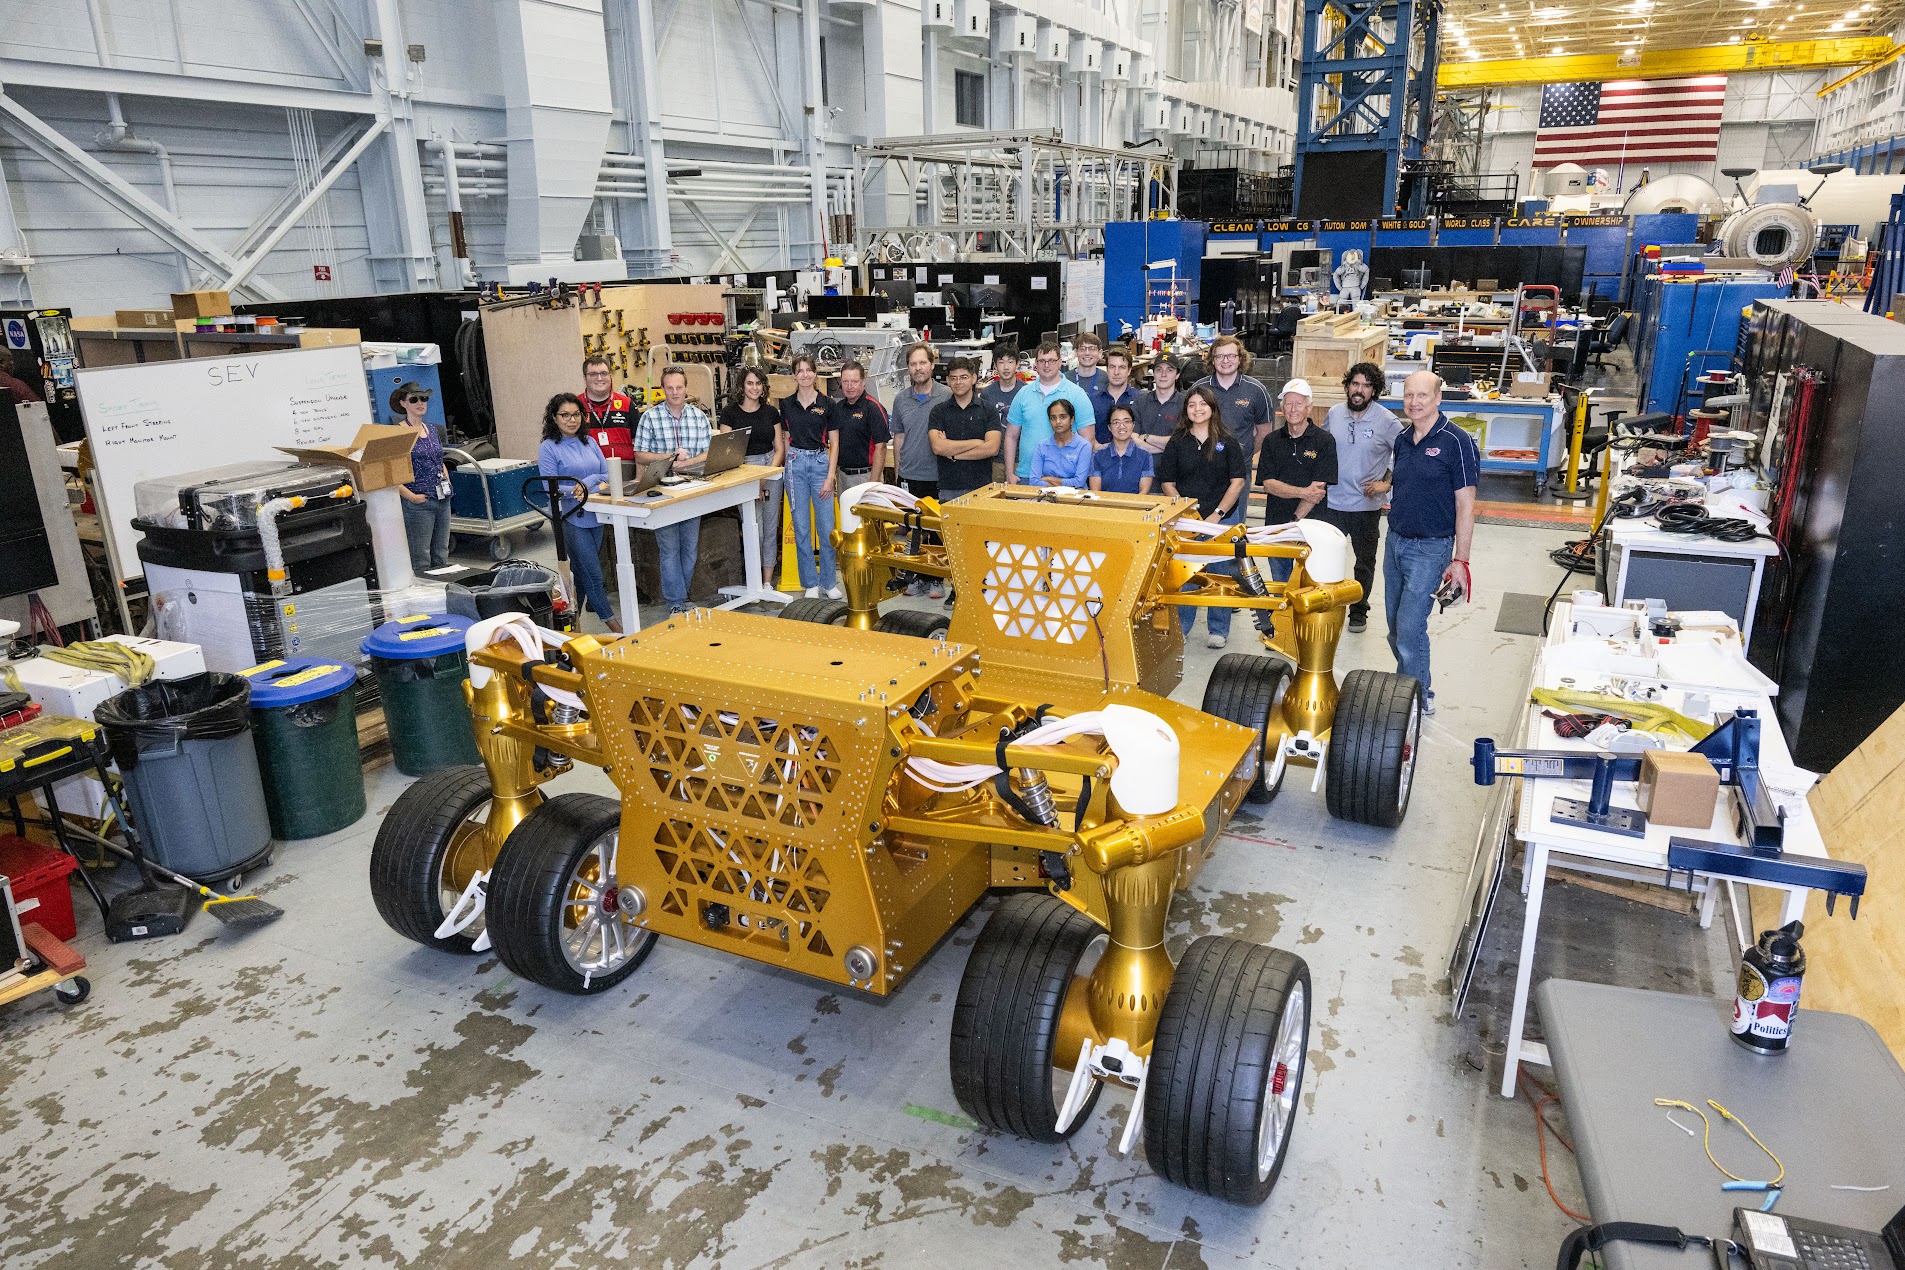
LTV 1
The LTV GTU engineering team on the chassis rollout day at NASA Johnson Space Center.
bottom of page